Husain Altelly · Robotics & AI student
Robotics.
From the
inside out.
Robotics & AI student at Khalifa University, graduating in 2028. I’m looking for a Summer 2027 internship in motion planning and perception.
Husain Altelly · Robotics & AI student
Robotics & AI student at Khalifa University, graduating in 2028. I’m looking for a Summer 2027 internship in motion planning and perception.
Hardware · Algorithms · Useful software
I’ve built a self-balancing robot, RRT and PRM motion planners and a tendon-driven gripper, and I’m now on the KURA RoboCup team working in ROS 2.
Abu Dhabi · Summer 2027 internships
I’m open to Summer 2027 internships in the UAE and abroad. I hold a UAE Golden Visa, so no visa sponsorship is needed in the UAE.
Selected work · Robotics
Physical hardware, planning algorithms, and the lessons that come from making them work.

01 / Sensing & control
I wrote the MicroPython control code that estimates the robot’s tilt and drives its wheels to keep it upright. Our best runs balanced for about 30 seconds.
02 / Algorithms & simulation
I implemented RRT and PRM planners in Python with A* roadmap search and visualized their routes. I ran 54 parameter configurations, 27 per planner.
03 / Mechanisms & actuation
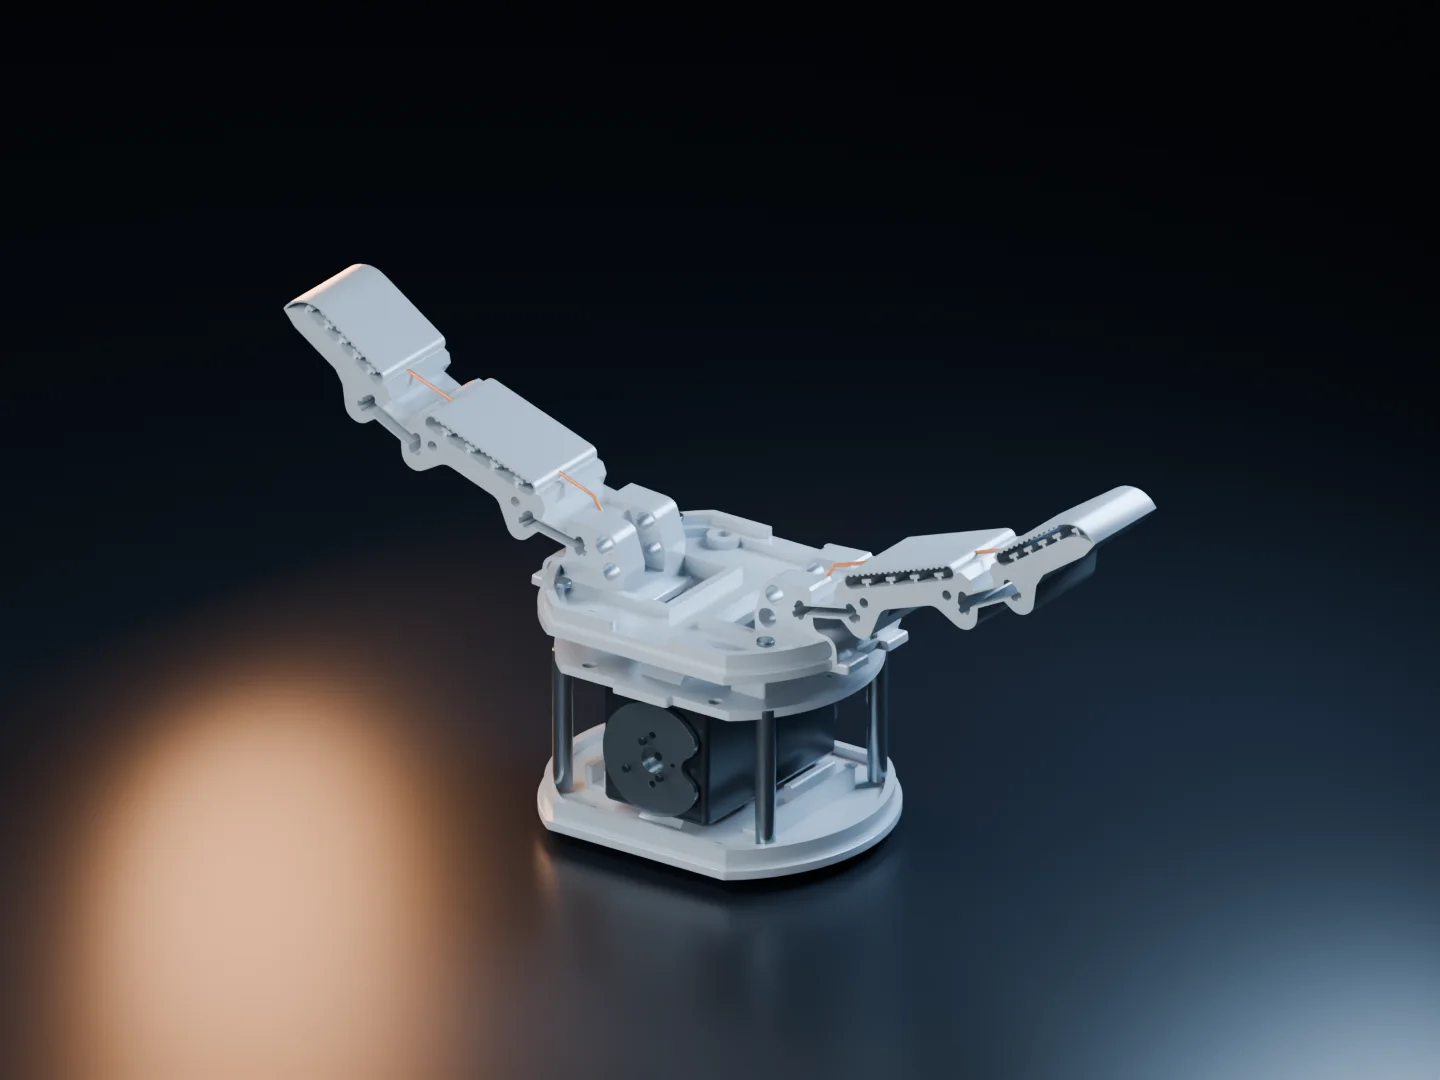
My team built the Model T42, an open gripper design from Yale OpenHand, and tested basic grasping. I ran the MATLAB analysis, routed the tendons and calibrated the Dynamixel motors.
Robotics labs
Course labs with recorded demos: LiDAR SLAM on a TurtleBot3 in simulation and on the real robot, plus servo and DC motor control in MicroPython.
ROBO 201 · October 2025
LiDAR-based SLAM in simulation and on the physical robot. ROS 2, Gazebo, RViz and Cartographer.
With Mohammed Muqeet and Wenke Li. I ran the mapping and localization in simulation and on the real robot.
TurtleBot3 mapping and localization, Motion Planning Algorithms for Robotics, October 2025.
Husain Altelly, Mohammed Muqeet and Wenke LiOpen on YouTube (TurtleBot3 · mapping & localization)ROBO 205 · April 2026
PIR-triggered servo movement and DC motor speed and direction control using MicroPython.
With Mohammed Muqeet.
PIR-triggered servo motor demonstration. ROBO 205 Lab 9, April 2026.
Husain Altelly and Mohammed MuqeetOpen on YouTube (PIR-triggered servo movement)DC motor speed and direction control. ROBO 205 Lab 9, April 2026.
Husain Altelly and Mohammed MuqeetOpen on YouTube (DC motor · speed & direction)Selected work · Software
Team prototypes that bring AI into conversation, practice, and playful exploration.

04 / Human-AI interaction
We built a desktop app for reviewing conversations, practicing responses and getting live coaching. It won the Most Useful track award.
05 / Educational simulation
We built an educational landing simulator with 14 stages, Gemini guidance and a separate Q-learning demo. It placed third.
More things I’ve explored
Team prototype · July to September 2026
A mobile prototype for family calendars and optional camera monitoring. My work included onboarding, clearer calendar and camera setup, regression tests, and Android workflow checks.
A local fall-detection demonstration was evaluated using staged trials.
Flutter · FastAPI · PostgreSQL
Hackathon prototype · 2026
A conversational prototype for navigating UAE services, transport and everyday questions, with links to official resources and optional saved links.
Next.js · TypeScript · Gemini · Supabase
Explore the sourceBeyond the projects

I’m Husain Altelly, a Robotics & AI student at Khalifa University in Abu Dhabi, graduating in May 2028. I build robots and the software behind them, from control loops and motion planners to AI prototypes. I’m on the KURA RoboCup team, working on ball tracking and goalkeeper prediction in ROS 2, and I’m Vice President of the KU Entrepreneurship & Innovation Club.
View CV (PDF)Through my lens
Architecture, light, and moments beyond the workbench.
Let’s connect
I’m especially interested in motion planning and perception, and open to roles in the UAE or abroad. I hold a UAE Golden Visa, so no visa sponsorship is needed in the UAE.
You can email me, or find my LinkedIn, GitHub and CV below.
HusainAltelly@outlook.comThe Blender scenes and animations are illustrations made for this portfolio, not recorded results. The YouTube videos show the real robots and lab demos, and the AURORA film includes footage from the interactive learning demo.
The T42 scene uses the Yale OpenHand Model T42 CAD from the Yale GRAB Lab’s OpenHand repository, licensed CC BY-NC 3.0, with the assembly, materials, tendon path and motion adapted for illustration.
R. R. Ma, L. U. Odhner, A. M. Dollar, “A Modular, Open-Source 3D Printed Underactuated Hand,” ICRA 2013.
The Yale OpenHand Project is an initiative to advance the design and use of robotic hands designed and built through rapid-prototyping techniques in order to encourage more variation and innovation in mechanical hardware. Please visit the Yale OpenHand site for more details.

